Coordinate robots and mobile fleets
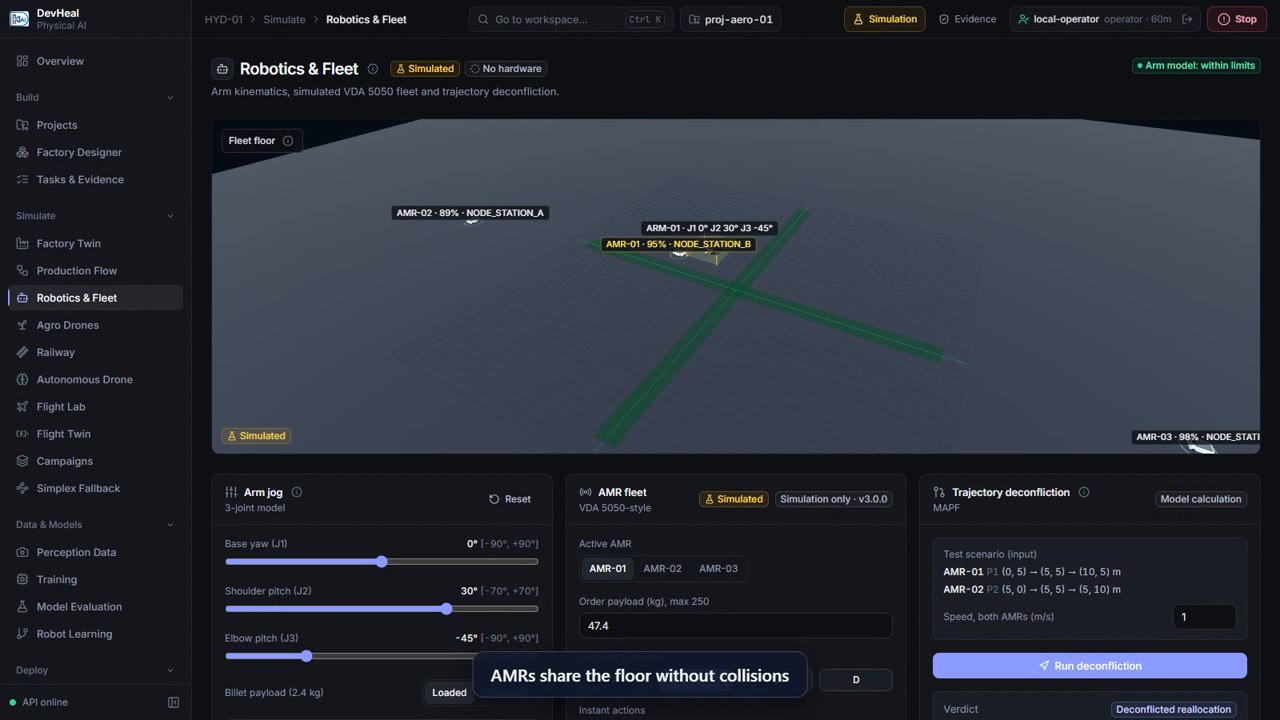
Explore robot arms and AMRs together, with path deconfliction, fleet coordination and grip-slip checks.
Bring robot arms, mobile fleets and learning workflows together. Teach a task, evaluate a policy and examine how machines interact in a shared environment.
Built in Hyderabad. Open to enterprise, technology and research partnerships.
Recorded demonstrations from the DevHeal console. Each workflow below includes a description and a playable simulation video.
Explore robot arms and AMRs together, with path deconfliction, fleet coordination and grip-slip checks.
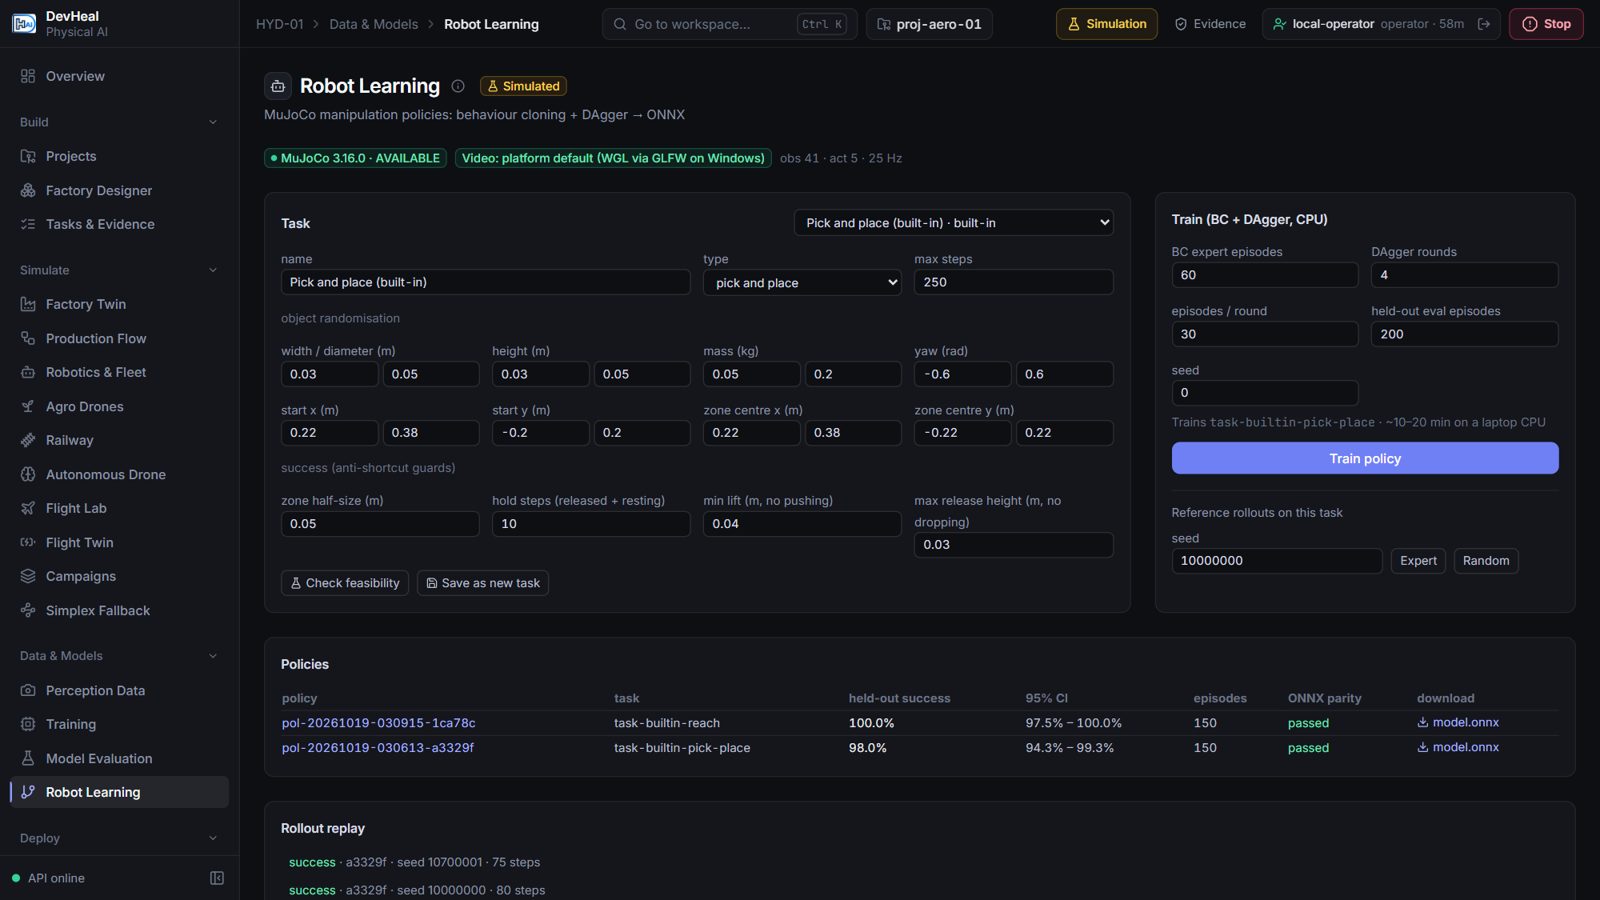
Train a manipulation policy in MuJoCo, evaluate it, and replay the resulting pick-and-place behaviour.
Inspect task feasibility, demonstration data, policy evaluation and rollout replay. Use simulation evidence to shape a supervised hardware-validation plan.
Explore a free pilot with DevHeal. We’ll agree a focused workflow, the data and integration requirements, and the measures that matter to your team.
The videos and screenshots show simulation workflows. Hardware integration and field performance are evaluated in supervised pilots; simulation results are not safety certification.